Robotics integration & field experience

AVATAR remote-operation fieldwork

My marine robotics experience includes AVATAR project work, connecting vessel requirements, control interfaces and field coordination.

Inland vessel · Remote operationSelected field-project experienceField-project experience
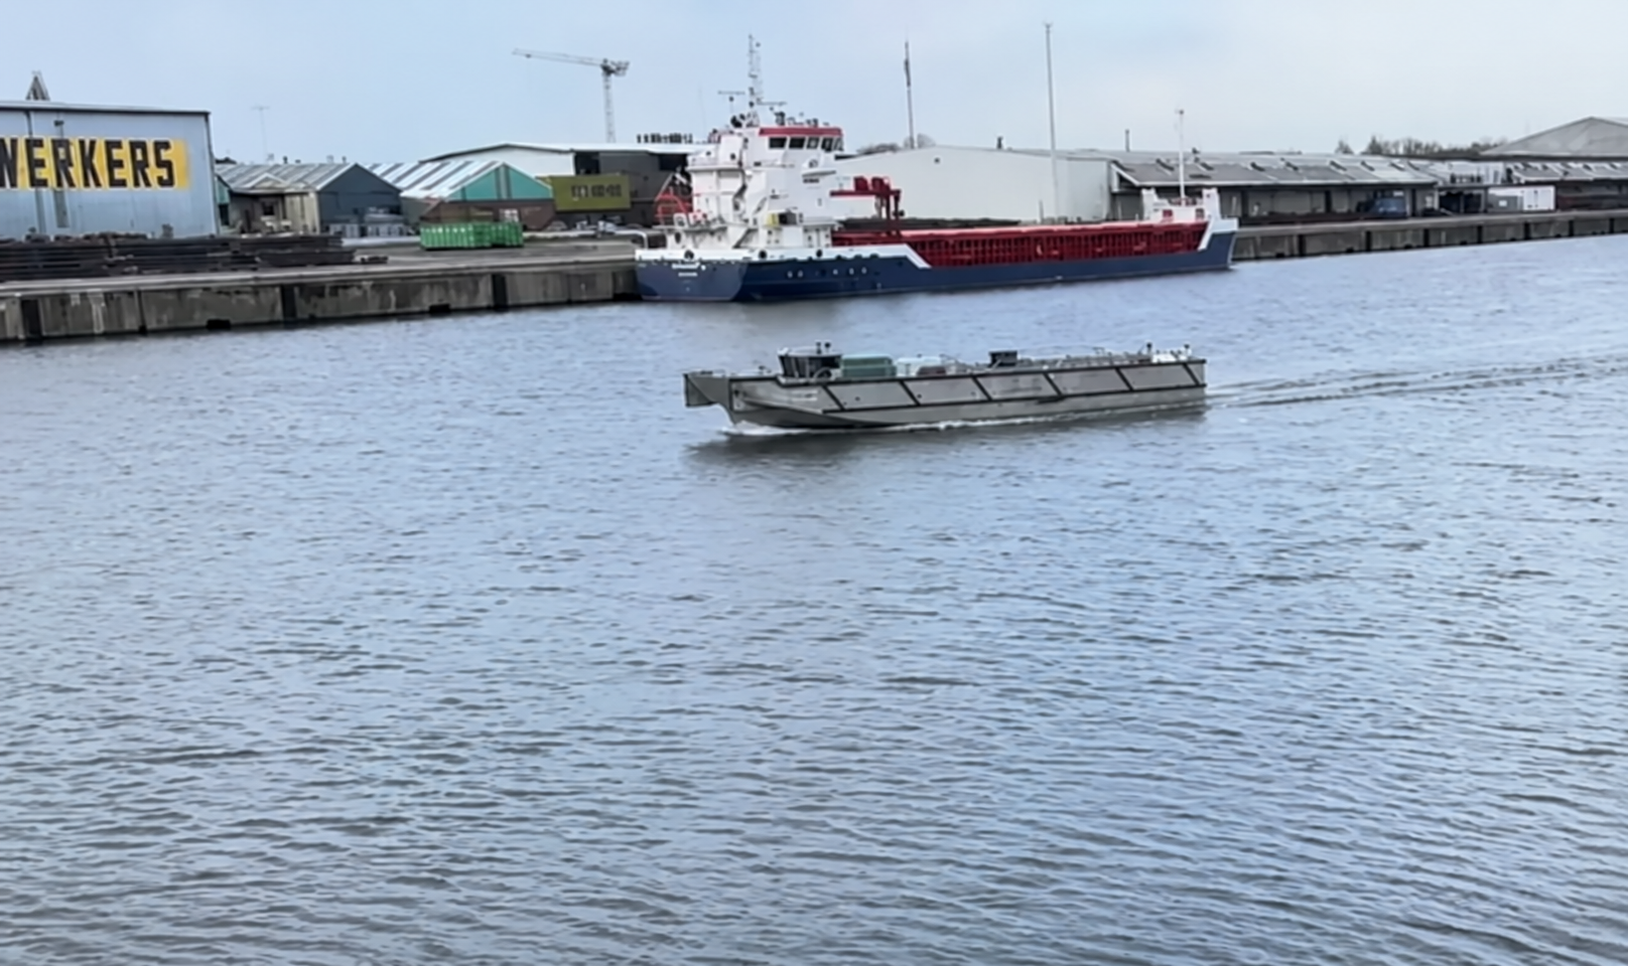
AVATAR vessel on port waters, in an AI-edited crop of original project imagery that excludes people
AVATAR field context. AI-edited crop of original project imagery to exclude people; used as a contextual illustration, not a test record.

The opportunity

How do vessel controls, positioning, communications and the operator interface come together for remote operation in a real waterway?

My contribution

My work covered requirements and interface planning, technical coordination and field support. I connected the operating needs with the engineering tasks and supplier inputs needed for the vessel system.

Concrete output

Vessel and remote-control field material, alongside system-integration and upgrade planning. The work connects remote command, vessel response, positioning, communications and the practical operator setup.

Evidence summary

The integration questions behind remote operation

FocusWorking summary
Vessel and controlDefine commands, response feedback, propulsion and steering interfaces.
Positioning and communicationsUnderstand positioning quality, communication coverage and link-loss handling.
Operator workflowClarify control authority, status information and the operating procedure.
Field validationRecord conditions, expected behaviour, observations and issues before expanding scope.

A concise summary of the case material, prepared for this portfolio.

Business relevance

Field experience informs the questions I bring to a robotics opportunity: which interfaces need integration, how the operator stays in control, and what testing and support the system requires.

Supporting evidence

Existing project imagery and planning

AVATAR vessel and remote-control field material

The original material shows the vessel, handheld controller and field setting. Upgrade documents describe further integration work; planned capabilities are separate from completed field activity.

Anonymised summary; underlying working material can be discussed in context.
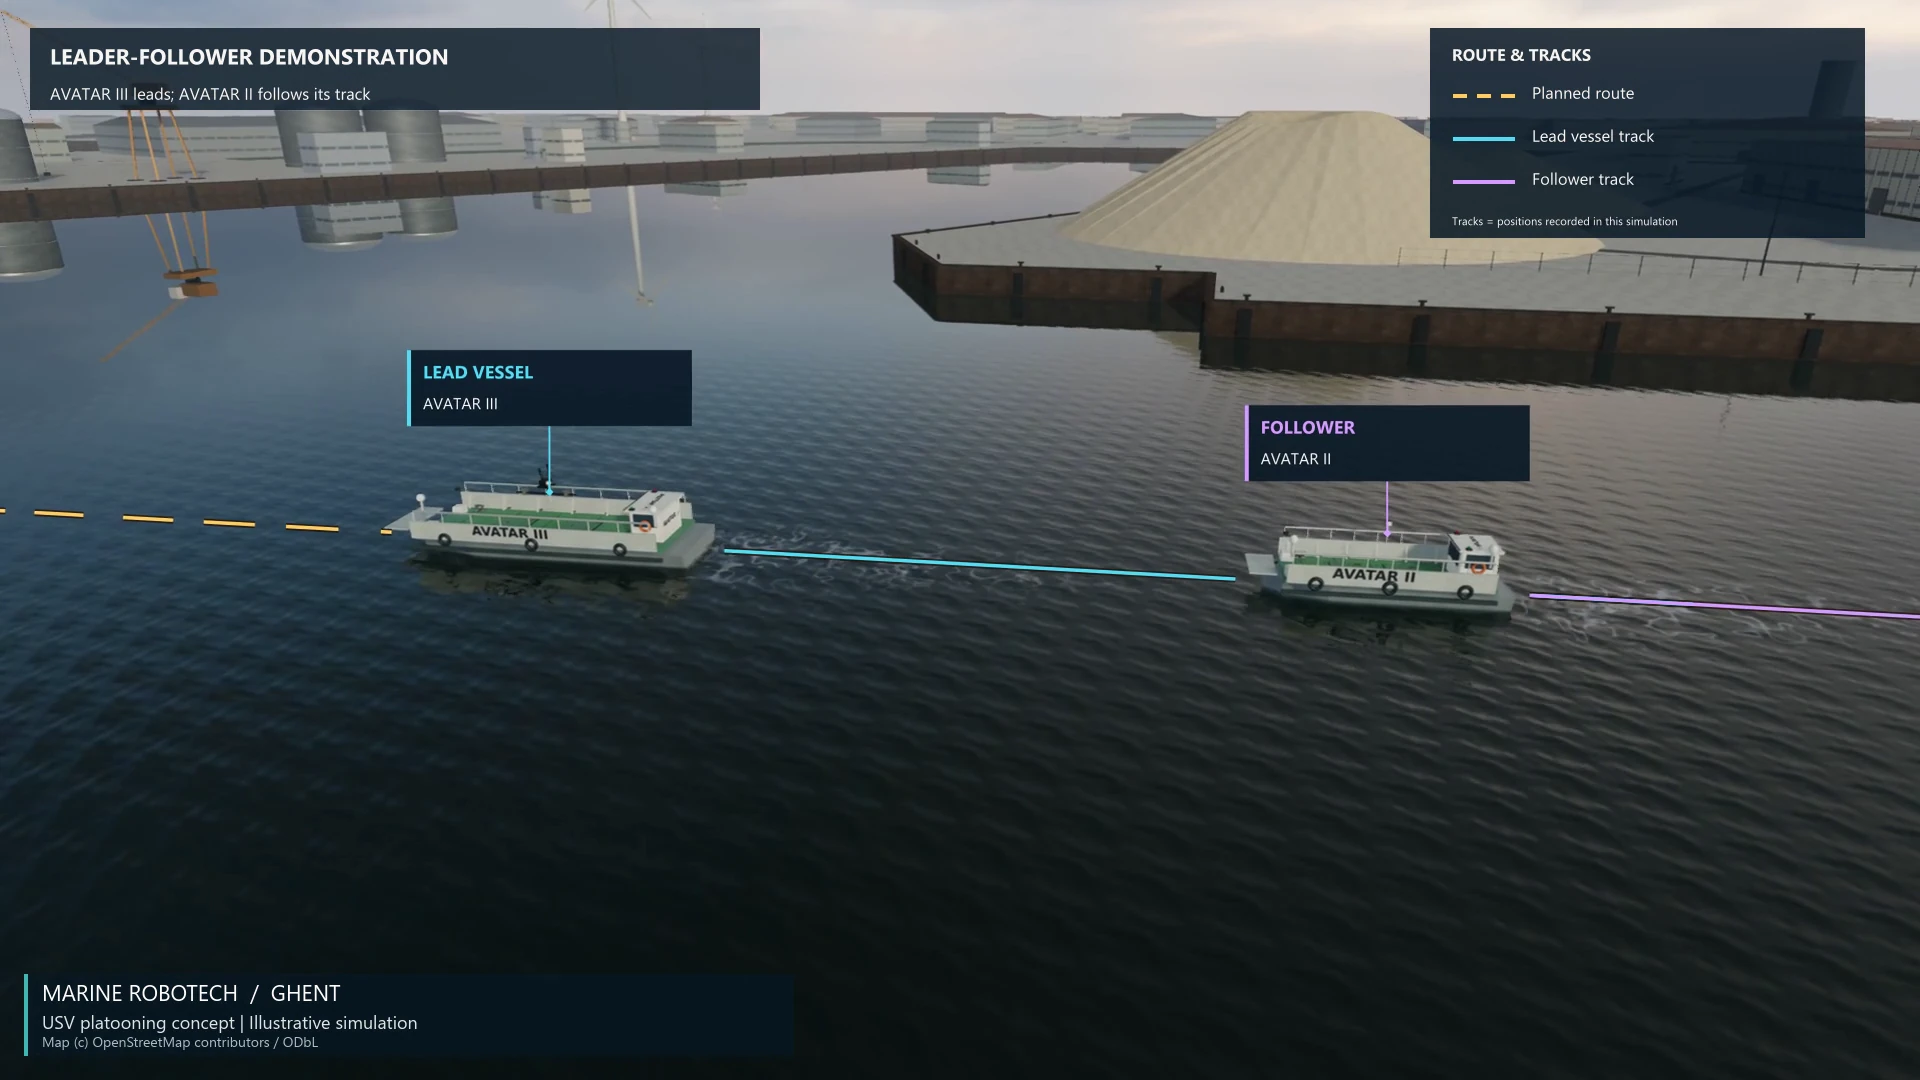
Current stage

The field material documents the vessel and remote-operation context. It does not establish certified autonomy, quantified performance or completion of every proposed upgrade. The newer perception prototype is a separate development.

The next step

For the next integration, define the command and feedback interfaces, operating limits, loss-of-link behaviour and acceptance tests before committing to an on-vessel trial.